01
The real robot interface
The AgiBot GDK in the pack-off cell, the Unitree low-level interface in WardZero. No simulation-only shortcuts in the code that moves the robot.
Work
We built these projects to show how we work: a packing line in a factory and a hospital, with a wheeled humanoid in one and a bipedal humanoid in the other. Both are at the simulation stage, and each case study says exactly what has and has not been tested.
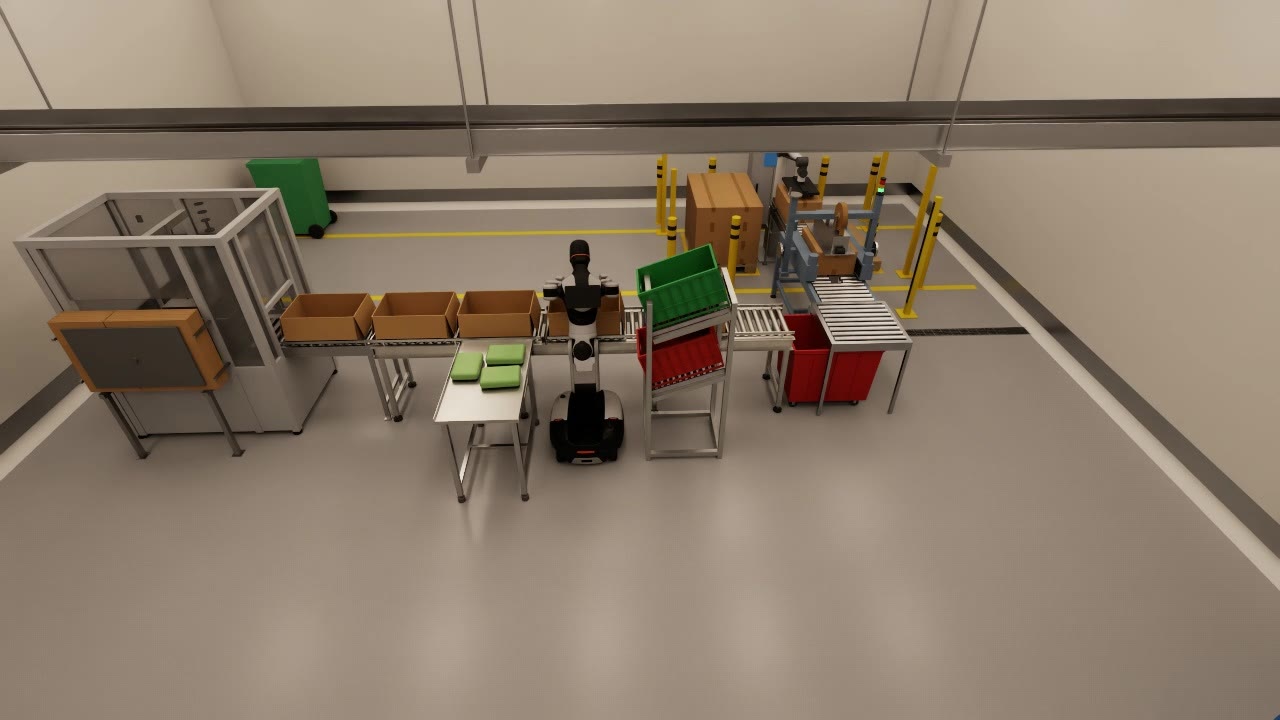
A wheeled humanoid at the end of a packing line. It picks sealed bags from a table, packs them into cartons on a conveyor and sorts rejects into totes, inside a full end of line with a case erector, a case sealer and a palletiser.
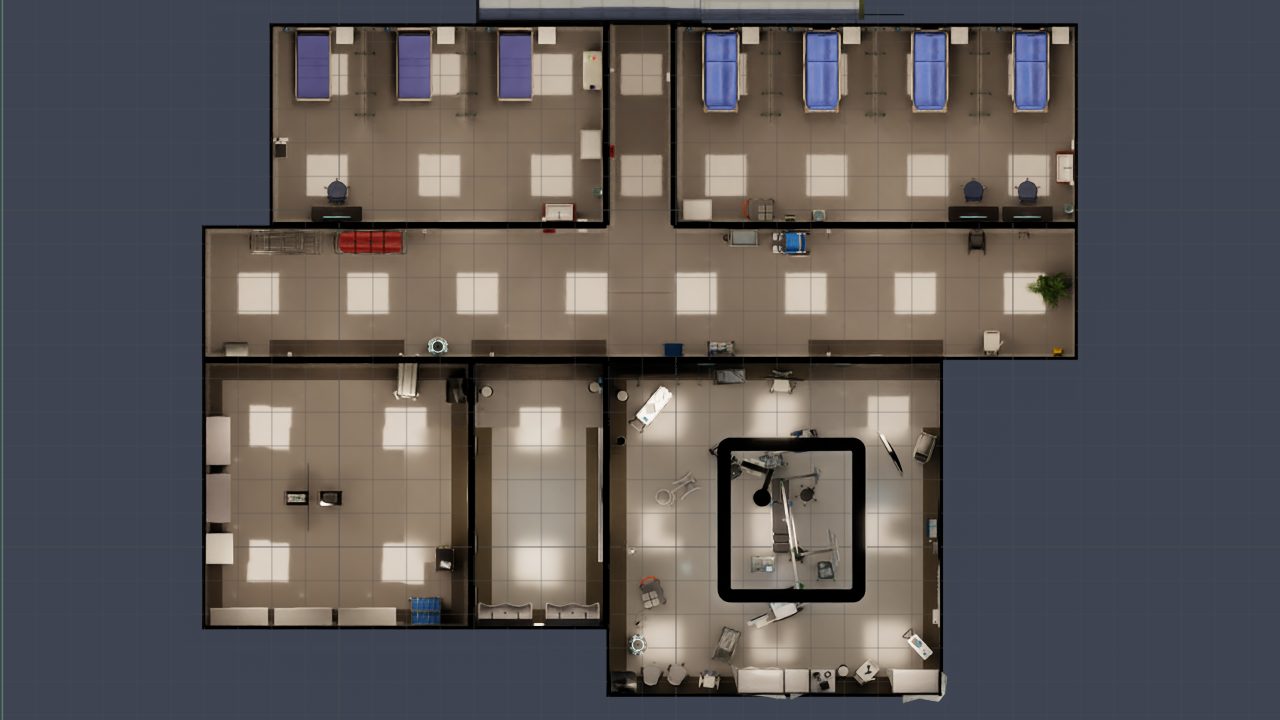
A simulated hospital where robots train before they meet patients. It has a surgical wing, a ward and a small A&E built to UK hospital guidance, fire doors and bed lifts with physics, and a Unitree G1 that runs the same software in two simulators.
What the two have in common
Different robots and different buildings, built the same way. These habits are what we bring to your site.
01
The AgiBot GDK in the pack-off cell, the Unitree low-level interface in WardZero. No simulation-only shortcuts in the code that moves the robot.
02
Each site comes from one generator file. Tests check reach, clearances and overlaps every time the site is rebuilt.
03
Every figure has a method behind it, and every page has a status section that lists what is still untested.
We are happy to walk you through either one, including the parts that are not finished.